# cad-agent

[![CI](https://github.com/Valpatel/cad-agent/actions/workflows/ci.yml/badge.svg?branch=main)](https://github.com/Valpatel/cad-agent/actions/workflows/ci.yml)
[![License: MIT](https://img.shields.io/badge/license-MIT-blue.svg)](https://github.com/Valpatel/cad-agent/blob/dev/LICENSE)

**Hardware design with AI agents, checked like engineering.** cad-agent turns a folder of CAD scripts into a
repeatable pipeline: build the parts, check the fit, simulate strength and airflow, and publish the evidence as
print files, reports and a linked review site. It works with Claude Code first, plus Codex, Cursor and Gemini.

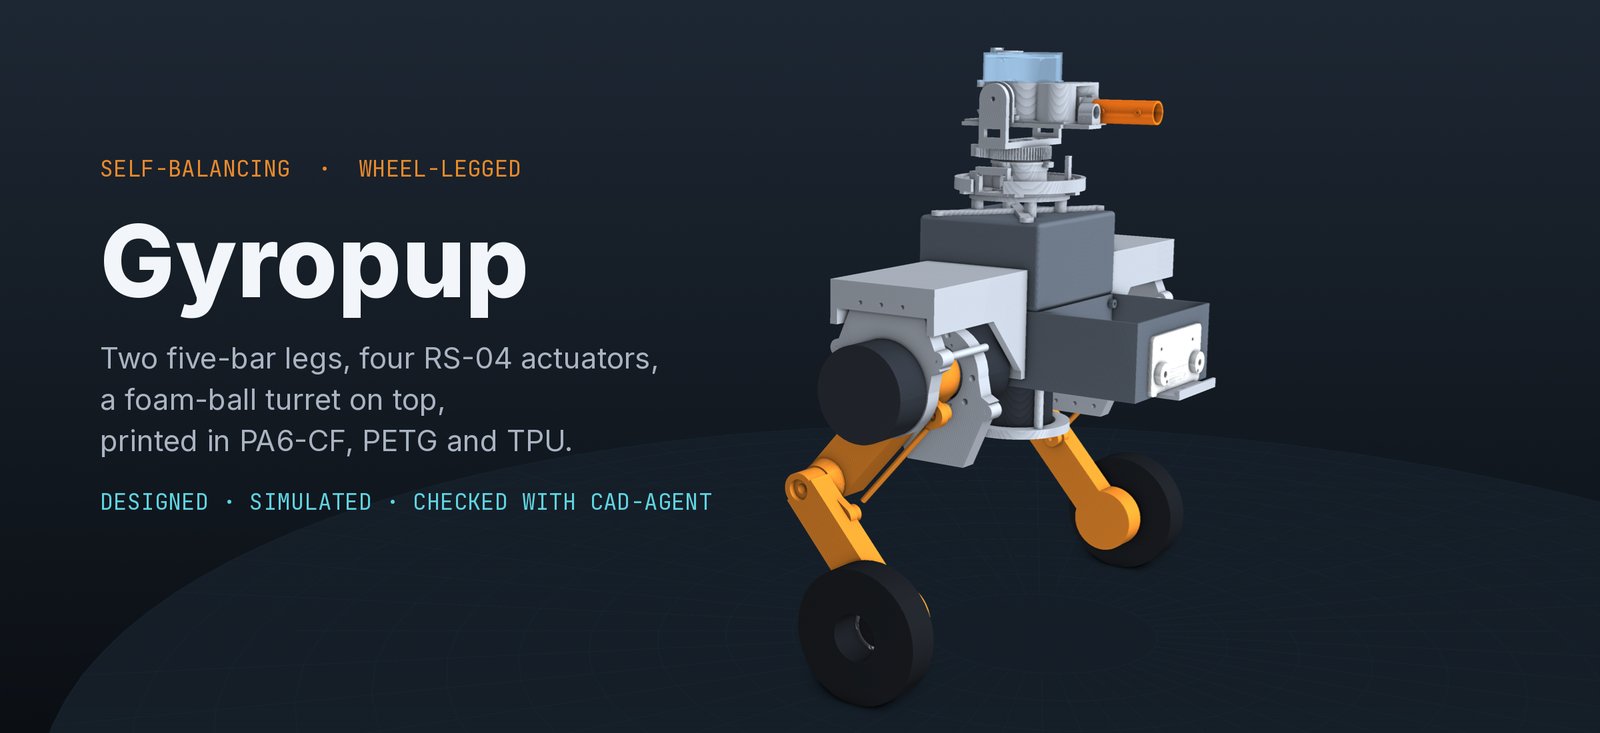
<p align="center"><img src="docs/img/gyropup.jpg" alt="Gyropup, a self-balancing wheel-legged robot designed with cad-agent" width="100%"></p>

<table>
<tr>
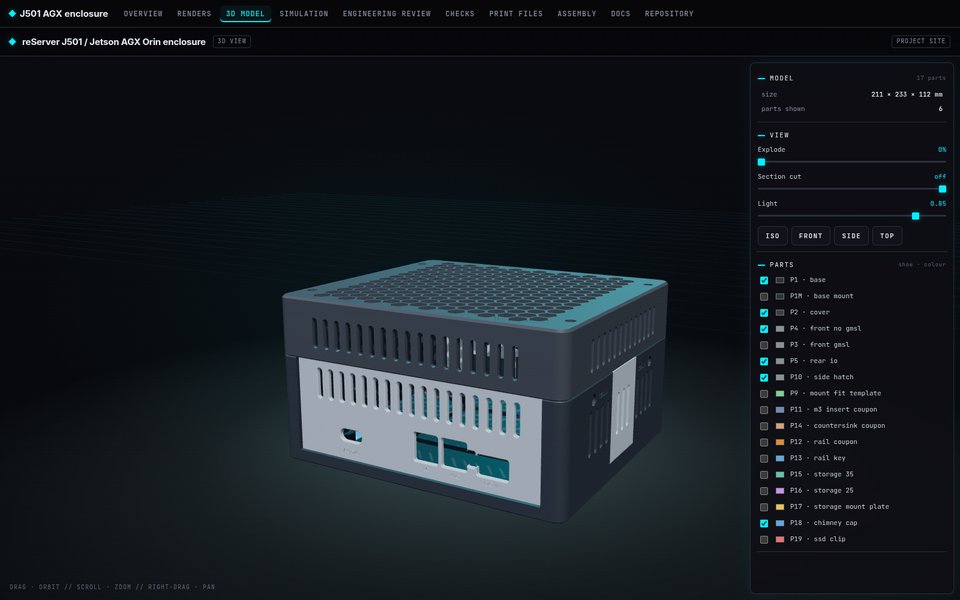
<td width="33%"><img src="docs/img/viewer.jpg" alt="3D viewer"><br><b>3D viewer and review site.</b> Every part in place, with explode, section and one top bar linking every report.</td>
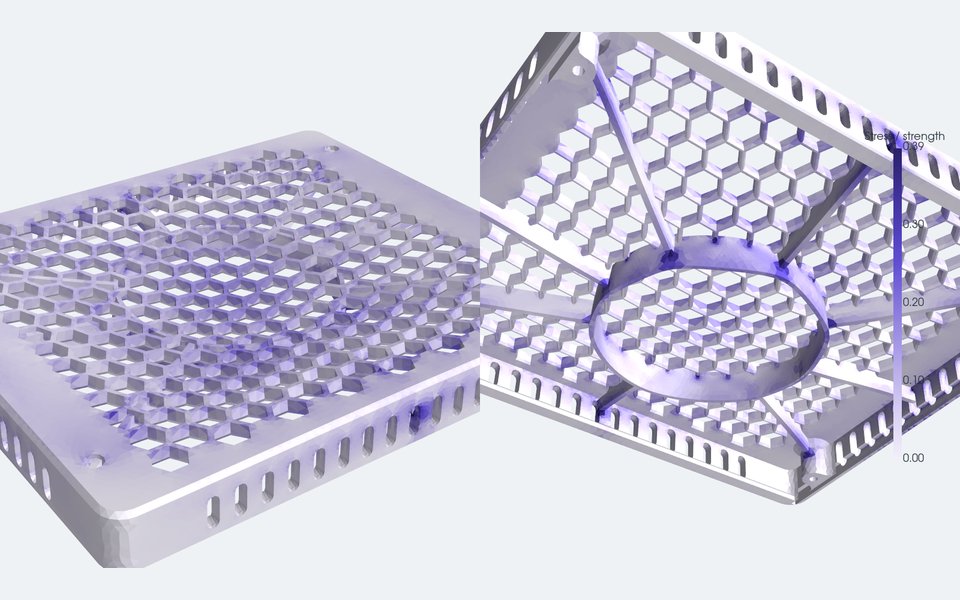
<td width="33%"><img src="docs/img/fea.jpg" alt="FEA of an enclosure lid"><br><b>Strength.</b> FEA of a ribbed lid under a 300 N press, coloured by stress as a fraction of the material's strength.</td>
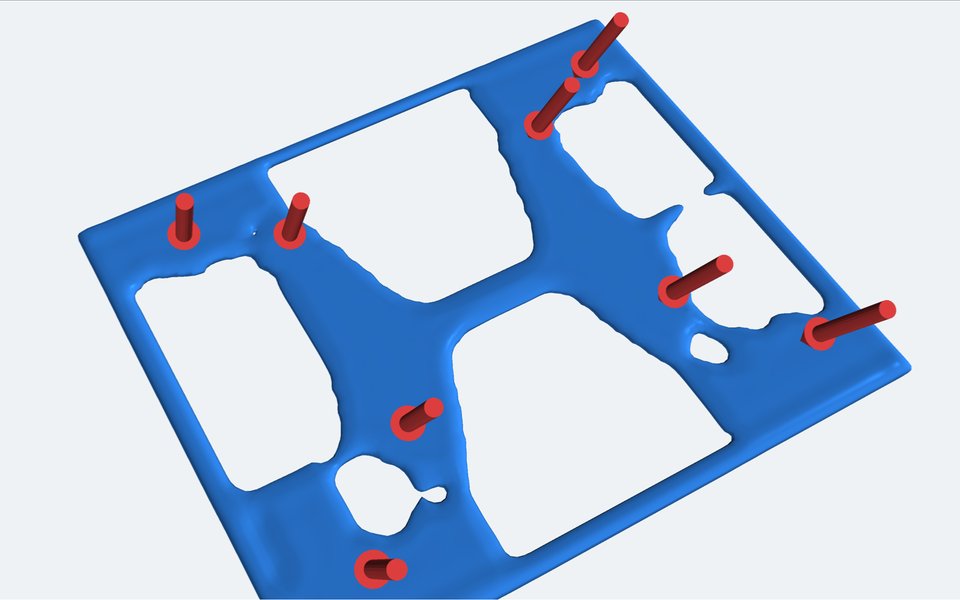
<td width="33%"><img src="docs/img/topology.jpg" alt="Topology optimisation of an enclosure floor"><br><b>Less material.</b> Topology optimisation keeps only the floor that carries load.</td>
</tr>
</table>

## How it works

A project describes itself in one `cad-agent.yaml`. cad-agent runs it and collects the proof.

```mermaid
flowchart LR
    P["📐 <b>Your project</b><br/>cad-agent.yaml<br/>CAD scripts · parameters"]
    B["🔧 <b>build</b><br/>CAD · checks · simulations<br/>run as ordered steps"]
    M["🖨️ <b>export-3mf</b><br/>bed-centred 3MF<br/>read back and verified"]
    R["✅ <b>check + report</b><br/>every result, pass or fail<br/>with its evidence"]
    Z["📦 <b>package</b><br/>review zip<br/>sha256 manifest"]
    W["🌐 <b>site --serve</b><br/>linked review site<br/>3D viewer · live reload"]
    P --> B --> M --> Z
    B --> R --> Z
    R --> W
    classDef src fill:#1f2933,stroke:#e8892b,color:#f5f7fa
    classDef step fill:#0e3a43,stroke:#00b8c8,color:#f5f7fa
    classDef out fill:#2a2440,stroke:#9d7bff,color:#f5f7fa
    class P src
    class B,M,R step
    class Z,W out
```

`cad-agent all` runs build, export-3mf, check, report and package in one go. It never claims a physical fit. A check
either has evidence or it says what is assumed.

**PCB and enclosure workbenches:** [PCB workflow](docs/pcb.md) covers embedded schematics, copper layers, assembly views and housing renders in the status page; native KiCad ERC/DRC/parity evidence; source freshness; and JLC BOM/CPL checks. Use `cad-agent pcb-check` to bind reports to source files. Qualification gates stay separate from CAD checks.

## What's in the box

```mermaid
flowchart LR
    D["✏️ <b>Design</b><br/>connectors · mcmaster<br/>robot · geometry · explore"]
    V["🧪 <b>Verify</b><br/>fea · cfd · heatsink<br/>topopt · slicer"]
    S["🖼️ <b>Show</b><br/>render · simviz · reports<br/>site · 3D viewer"]
    P["📦 <b>Ship</b><br/>STL · STEP · 3MF<br/>hashed review zip"]
    D --> V --> S --> P
    classDef g fill:#14232b,stroke:#3a8fa3,color:#e8edf5
    class D,V,S,P g
```

| | Module | What it gives you |
|---|---|---|
| ✏️ | `connectors` | Port windows derived from the modelled mating plug, then a sweep check that the plug really goes in |
| ✏️ | `mcmaster` | The manufacturer's STEP and specs for a McMaster-Carr part number, normalised for assembly |
| ✏️ | `robot` | Mass properties from CAD, links and joints, URDF and MuJoCo export, meshes kept under budget |
| ✏️ | `dossier` | The design dossier: requirements, sections, part spec cards, interfaces and decisions with the alternatives rejected, in YAML with `file:line` errors; build-script declarations of parts, cavities, joints, fasteners and assembly steps, exported for the gates; a lint and a per-section status (draft to signed off, voided when the geometry changes) from `cad-agent dossier` ([guide](docs/dossier.md)) |
| ✏️ | `gates` | Integrity gates on the assembly: floating parts and unrealised interfaces, items outside their cavity, fastener seat, engagement, tip and tool reach, motion-range collisions, assembly order and access, minimum walls. `cad-agent gates` runs them in parallel processes, writes verdicts bound to the geometry they checked, and `check` fails on a failing or stale one ([guide](docs/gates.md)) |
| ✏️ | `explore` | Part catalogues with prices and sources, designs that pick a part per slot, the project's own evaluator, Pareto ranking of the trade-offs, one-part swaps and a search over parts and parameters ([guide](docs/explore.md)) |
| 🧪 | `fea` | gmsh + scikit-fem linear elasticity with printed-material allowables, checked against textbook cases |
| 🧪 | `compliant` | Snap-fit sizing and checks (cantilever, torsion, annular) by the Covestro/Bayer method, tested against the guide's worked examples; allowable strain for moulded resins and, by print direction, for 13 filaments from their datasheets ([guide](docs/compliant.md)) |
| 🧪 | `cfd` | Conjugate heat transfer cases for OpenFOAM written from CAD: fans, fin blocks, heat sources |
| 🧪 | `heatsink` | Plate-fin correlations, fan operating point and porous-block coefficients for CFD |
| 🧪 | `topopt` | pyMOTO topology optimisation (SIMP, MMA, overhang filter) to cut filament where it does no work |
| 🧪 | `slicer` | Bambu Studio's command line for real filament grams and print time |
| 🖼️ | `render`, `simviz` | Off-screen renders, stress and flow pictures, MP4 animations; a review packet per dossier section (solid, x-ray, cuts through cavities, joints and screws, exploded along the assembly steps, joint range ends, gate findings at their witness points) with the measurements first and the render checklist, from `cad-agent review-packet` ([guide](docs/review-packet.md)) |
| 🖼️ | `report`, `simreport` | Results JSON and standalone HTML reports that name their limits |
| 🖼️ | `site`, `view`, webkit | A local review site with progress, decisions, docs and a 3D viewer, all under one top bar |
| 📦 | `mesh3mf`, `package` | 3MF writing with an independent read-back, and a hashed review zip |

The full guide, the `cad-agent.yaml` format and every command are in [`docs/toolkit.md`](docs/toolkit.md).

## Quick start

```bash
git clone https://github.com/Valpatel/cad-agent && cd cad-agent
pip install -e ".[cad]"                      # add fea, sim, robot, site as needed
cad-agent all --project path/to/your-project  # build, 3MF, check + report, package
cad-agent site --serve --project path/to/your-project
```

| Extra | Adds |
|---|---|
| `cad` | CadQuery, trimesh, VTK: building, checking and rendering parts |
| `fea` | gmsh, scikit-fem, PyPardiso: stiffness and strength |
| `sim` | PyVista, pyMOTO, manifold3d: airflow cases, topology optimisation, pictures and videos (OpenFOAM and Bambu Studio run as separate programs) |
| `robot` | MuJoCo, for robot export |
| `site` | Markdown, for the review site |
| `explore` | optuna, for the NSGA-II and TPE searches of `cad-agent optimise` (random and grid need nothing) |

## Built with cad-agent

| Project | What it is |
|---|---|
| [J501 AGX enclosure](https://github.com/mvalancy/j501-agx-orin) | A printed enclosure for the Seeed reServer J501 with a Jetson AGX Orin: port windows from mating plugs, FEA, airflow and topology-optimised floor vents |
| [Gyropup](https://github.com/Valpatel/gyropup) | A self-balancing wheel-legged robot with a foam-ball turret: five-bar legs, McMaster hardware, strength and fall studies |
| AGX Thor CAN boards | PCB and enclosure reviews |

Anything specific to one product stays in that product's repository. cad-agent only holds what every project can use.

## How cad-agent grows

```mermaid
flowchart LR
    A["🔎 <b>Adopt</b><br/>the best public tools,<br/>pinned and security-reviewed"]
    L["🧠 <b>Learn</b><br/>rules mined from real<br/>design sessions"]
    E["📏 <b>Evaluate</b><br/>tasks with machine-checked<br/>acceptance criteria"]
    G["🧩 <b>Fill the gaps</b><br/>only what nobody<br/>else provides"]
    A --> E
    L --> E
    E --> G
    G -.->|upstream PRs| A
```

- **Adopt.** Six upstreams are vendored under `vendor/`, pinned by commit, scanned and updated weekly through a
  reviewed process ([`SECURITY.md`](https://github.com/Valpatel/cad-agent/blob/dev/SECURITY.md), [`WEEKLY-UPDATE.md`](https://github.com/Valpatel/cad-agent/blob/dev/WEEKLY-UPDATE.md)): text-to-cad,
  kicad-happy and kicad-mcp-pro (MIT), and build123d-mcp, agentcad and bd_warehouse (Apache-2.0). OpenFOAM (GPL)
  and Bambu Studio (AGPL) run only as separate programs. gmsh (GPL) is imported, but only by the optional `fea`
  extra. Licences are in [`THIRD_PARTY_NOTICES.md`](THIRD_PARTY_NOTICES.md).
- **Learn.** [`lessons/`](https://github.com/Valpatel/cad-agent/tree/dev/lessons/) holds eleven sets of rules mined from real design sessions, each citing its source.
  They cover verifying from source, connectors, fasteners, evidence, simulation and material.
- **Evaluate, then fill the gaps.** Each tool is scored on the same tasks. What wins gets adopted, the gaps go
  upstream, and only what nobody else provides lives here.

## Contributing

Several projects and AI agents use cad-agent at once, so every change goes through a pull request.

```mermaid
gitGraph
    commit id: "v0.1"
    branch dev
    checkout dev
    commit id: "integration"
    branch feature
    checkout feature
    commit id: "change + tests"
    commit id: "review fixes"
    checkout dev
    merge feature id: "PR: CI + review"
    checkout main
    merge dev id: "release PR" tag: "vX.Y.Z"
```

1. Work in your own worktree on `feat/<topic>`, branched from `dev`.
2. Open a PR into `dev`. CI runs `core` on Python 3.10 and 3.12, and `full` with every extra.
3. A person or a separate review agent reviews it. Every comment is answered and resolved before the merge.
4. Releases go from `dev` to `main` by PR. Both branches are protected.

Details are in [`CONTRIBUTING.md`](CONTRIBUTING.md). Rules for AI agents are in [`AGENTS.md`](https://github.com/Valpatel/cad-agent/blob/dev/AGENTS.md).

## Layout

| Folder | What is in it |
|---|---|
| [`src/cadagent/`](https://github.com/Valpatel/cad-agent/tree/dev/src/cadagent/) | The toolkit, with its web kit in `webkit/` |
| [`tests/`](https://github.com/Valpatel/cad-agent/tree/dev/tests/) | The test suite, which also runs in CI |
| [`docs/`](https://github.com/Valpatel/cad-agent/tree/dev/docs/) | [`toolkit.md`](docs/toolkit.md), the guide to the toolkit, [`explore.md`](docs/explore.md), design exploration, and [`dossier.md`](docs/dossier.md), the design dossier |
| [`examples/`](https://github.com/Valpatel/cad-agent/tree/dev/examples/) | Worked examples: [`explore-two-wheel`](https://github.com/Valpatel/cad-agent/tree/dev/examples/explore-two-wheel/) compares robot configurations |
| [`skills/`](https://github.com/Valpatel/cad-agent/tree/dev/skills/), [`agents/`](https://github.com/Valpatel/cad-agent/tree/dev/agents/) | Agent skills and subagents for Claude Code and Codex: work tracking, PR review, remote runs, the section-by-section design process ([`design-process`](skills/design-process/SKILL.md)) and McMaster parts ([agent workflow](docs/agent-workflow.md); `cad-agent agents install`) |
| [`lessons/`](https://github.com/Valpatel/cad-agent/tree/dev/lessons/) | Rules mined from design sessions, with their sources |
| [`research/`](https://github.com/Valpatel/cad-agent/tree/dev/research/) | Landscape surveys, including the simulation tools |
| [`upstreams/`](https://github.com/Valpatel/cad-agent/tree/dev/upstreams/), [`vendor/`](https://github.com/Valpatel/cad-agent/tree/dev/vendor/) | The tool registry and the vendored, pinned upstreams |
| [`tools/`](https://github.com/Valpatel/cad-agent/tree/dev/tools/), [`mining/`](https://github.com/Valpatel/cad-agent/tree/dev/mining/) | Vendor sync, security scan and the local session miner |

## License

MIT. See [`LICENSE`](https://github.com/Valpatel/cad-agent/blob/dev/LICENSE). Vendored code keeps its own licence, listed in
[`THIRD_PARTY_NOTICES.md`](THIRD_PARTY_NOTICES.md).